Cover image

A Richer Map Can Make the Planner Slower

TL;DR for operators A robot can perceive more of its environment than its planner should necessarily receive. In the experiments summarized here, adding task-irrelevant objects to structured scene representations increases the burden on classical planners and can leave harder problems unsolved. The proposed response is not a new end-to-end planner. It is a learned relevance layer that decides which objects and relations should survive into the planning problem. ...
September 7, 2026 · 7 min · Zelina
Cover image

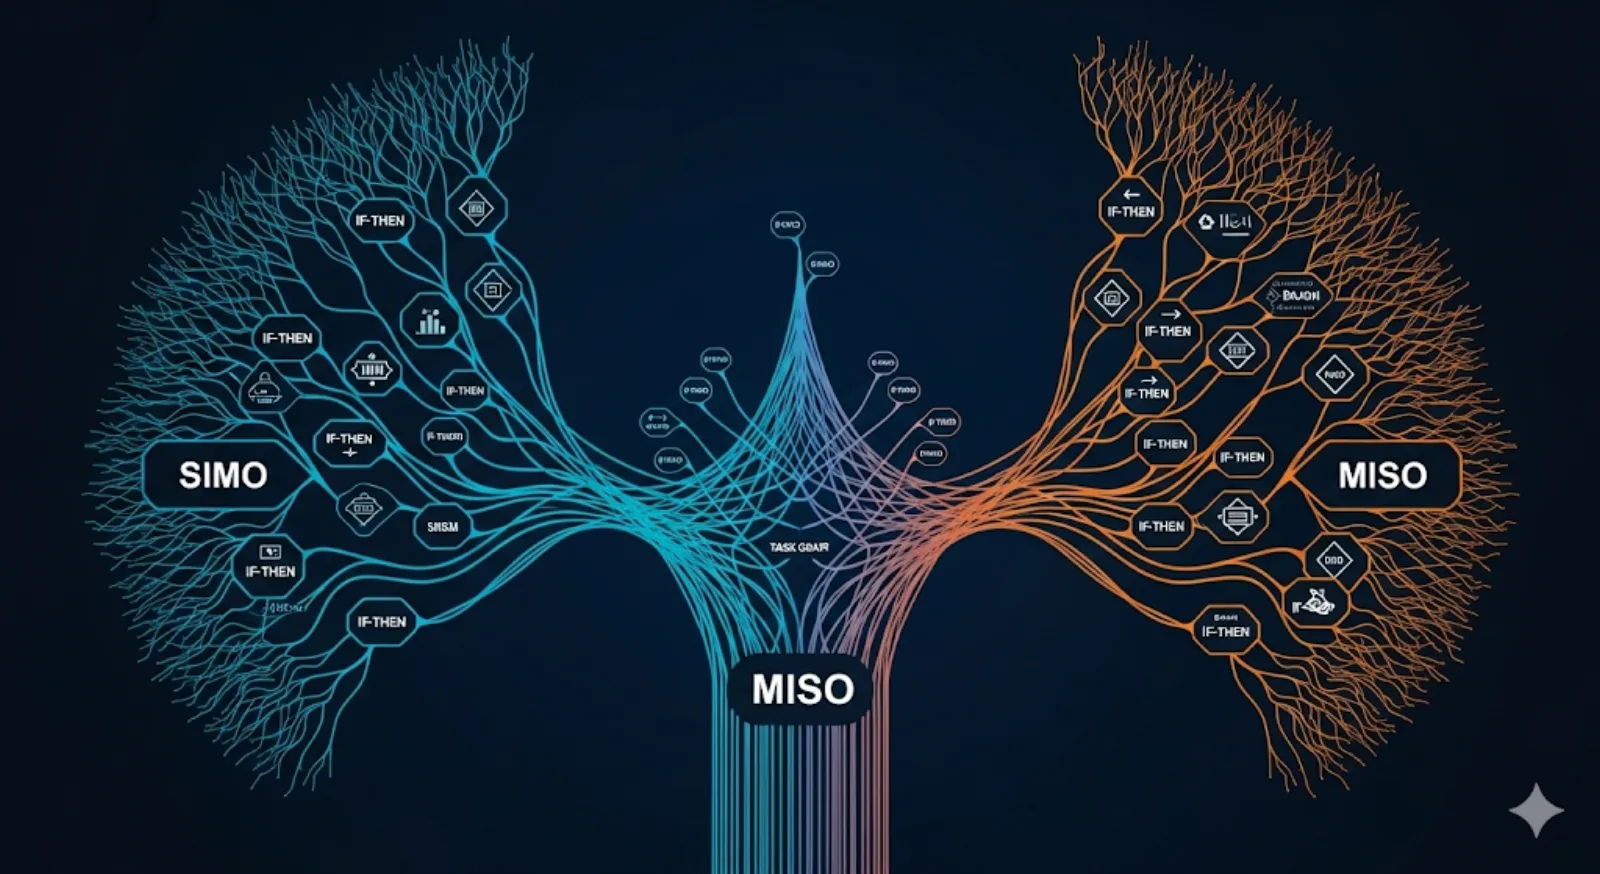
Fork, Fuse, and Rule: XAgents’ Multipolar Playbook for Safer Multi‑Agent AI

A bad agent stack often looks suspiciously like a bad committee. One agent proposes a plan. Another wanders into a neighbouring topic. A third confidently supplies a detail that is almost right, which is a particularly expensive genre of wrong. Then the system fuses the outputs, declares victory, and leaves the human operator to discover that “collaboration” was just error propagation wearing a nicer blazer. ...

September 19, 2025 · 14 min · Zelina