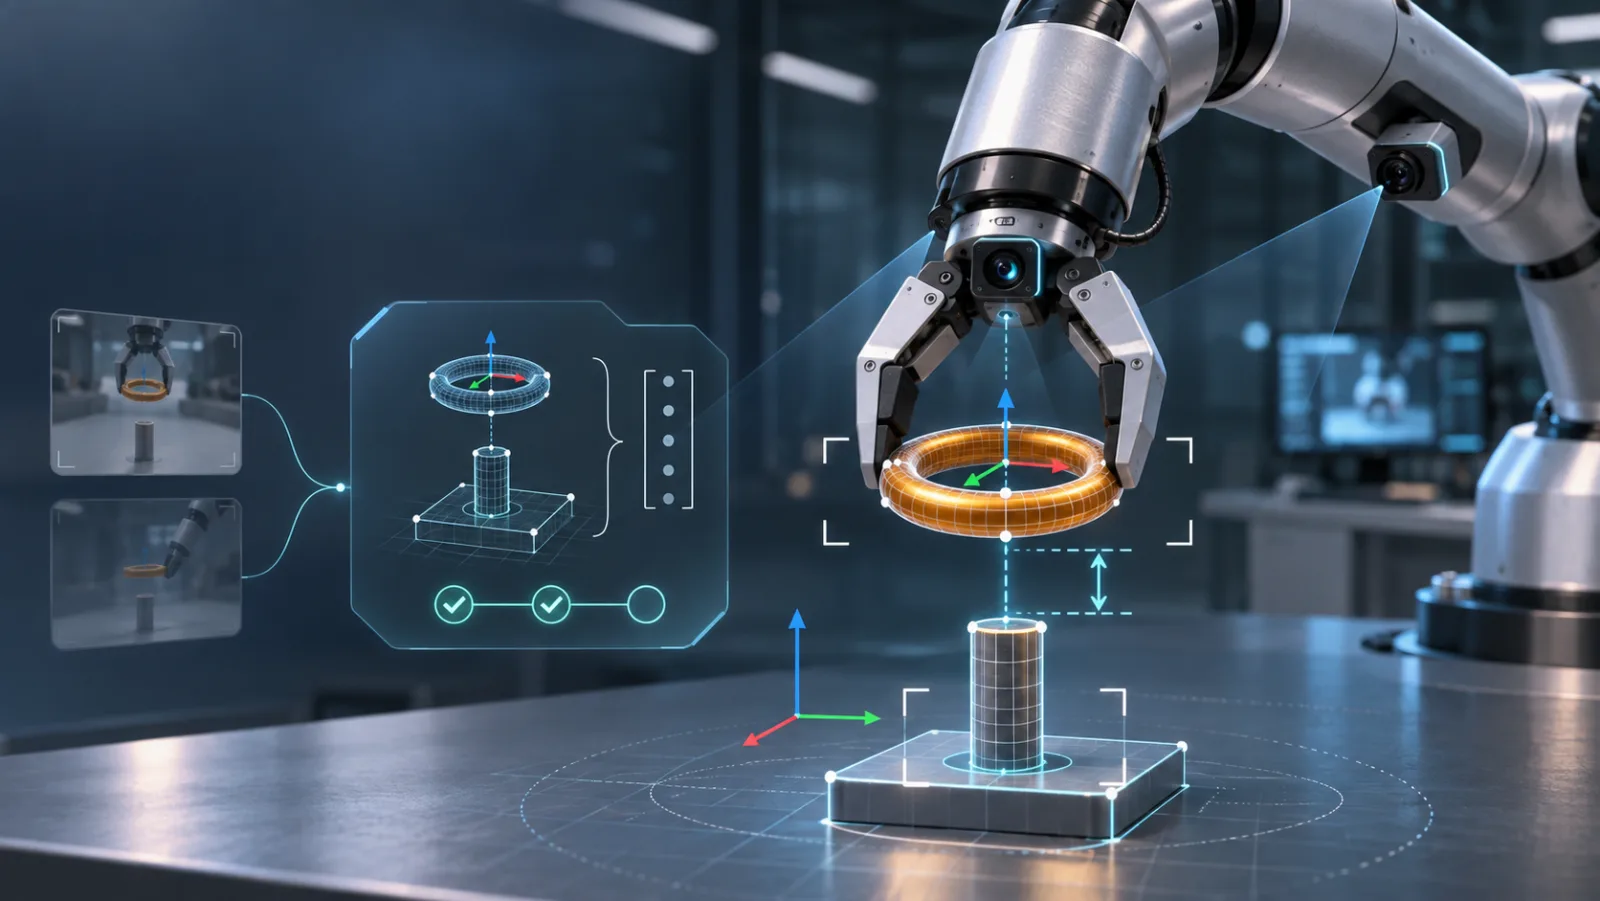
The Robot Still Sees. The Agent Needs Fewer Images.
TL;DR for operators Robot agents do not necessarily need a fresh camera image sent to the language model after every manipulation step. They need current, actionable spatial information—and a reliable indication of when that information is missing. A new geometric-abstraction system maintains 3D object state locally, exposes reusable references to object parts, and reports measured progress through textual checkpoints. In simulated robot manipulation, it improves completion rates substantially on construction and relocation tasks. On ring placement, mean capped completion time falls by 33.3%, while recorded token consumption falls by 52.8%. ...