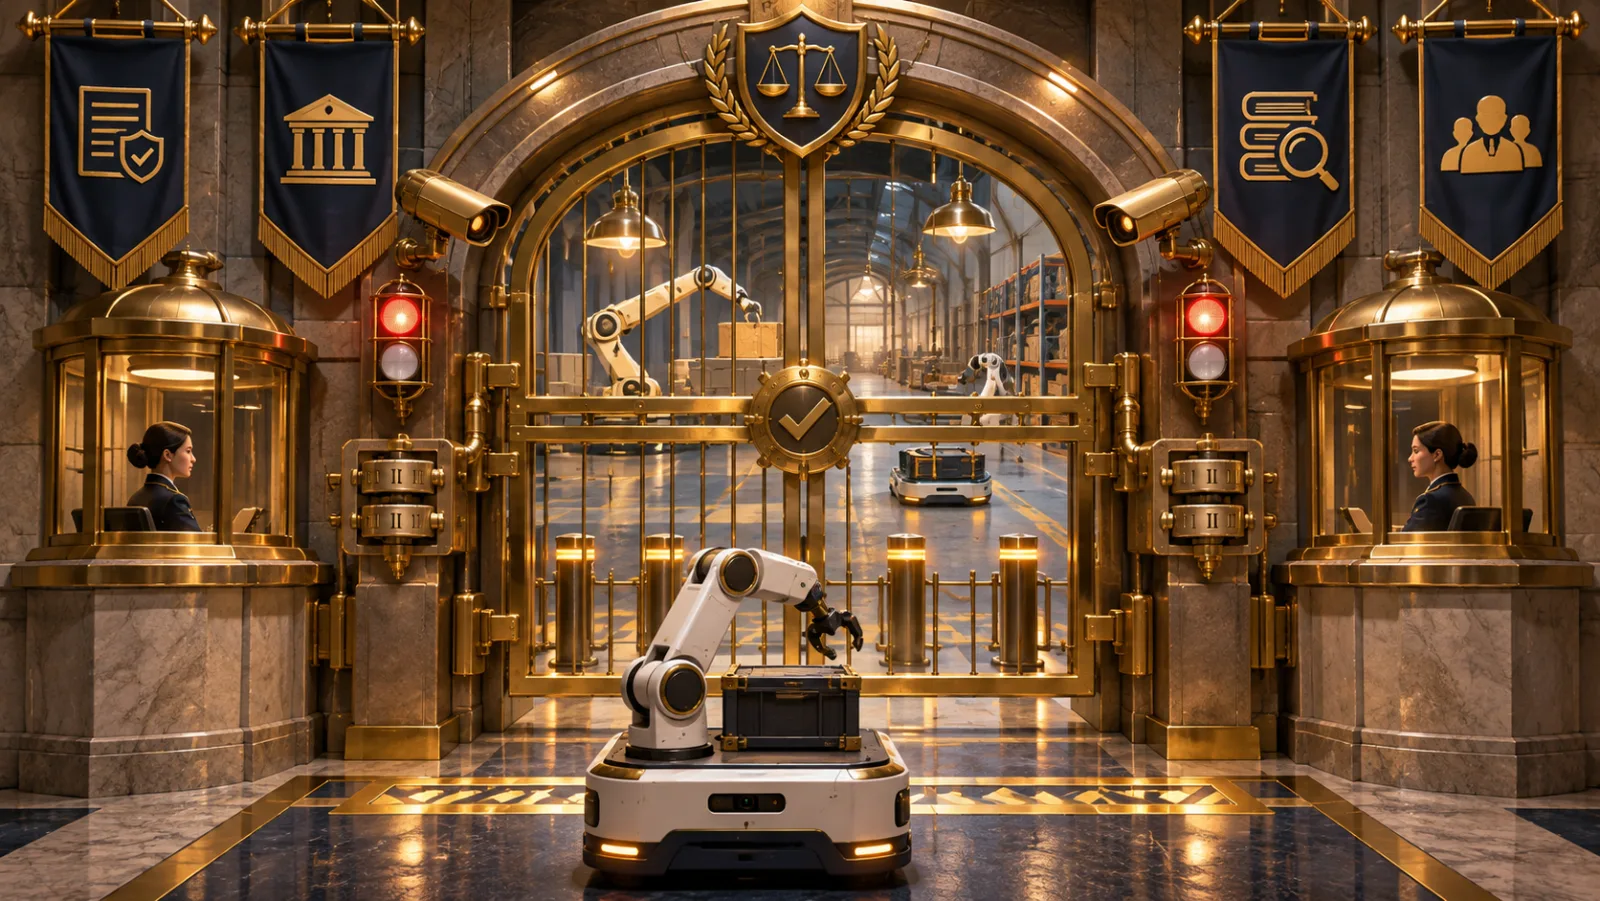
A Robot's Prediction Is Not Permission to Move
TL;DR for operators A robot’s learned model may generate an appropriate action while the surrounding system executes it too late, uses outdated context, or fails to interrupt it. One paper formally explains why model outputs and executable policies are different objects. Another demonstrates that spatial tools, concurrent execution, and motion-permission controls can materially change navigation outcomes. ...